Day 03Report
🇸🇬 Singapore Trip Report — Day 3
- Date
- 08 September 2026
- Location
- Singapore
- Reading time
- 6 min read
- Photos
- 22 Photos
Day 03Report
First actual training day at ITE College East. Today was all about the mBot — a small educational robot we programmed with block-based code (mBlock). Felt like being back in primary school but way cooler because there's a real robot rolling around in front of you.
Quick breakfast at the hotel, formal outfit on, out the door. The chartered coach picked us up right outside the hotel and drove straight to campus — about 45 minutes heading east through the city. Hot already at 8 AM, but the bus AC was cranked all the way up.
Arrived at the campus. It's huge — like a small town. Modern buildings, glass everywhere, clean layout, colour-coded sections. Got name badges, signed in, and sat through the welcome briefing where instructors laid out the week's programme: AI Essentials, Prompt Engineering, Drone Programming, and AI Robotics. Today's block: mBot robotics.
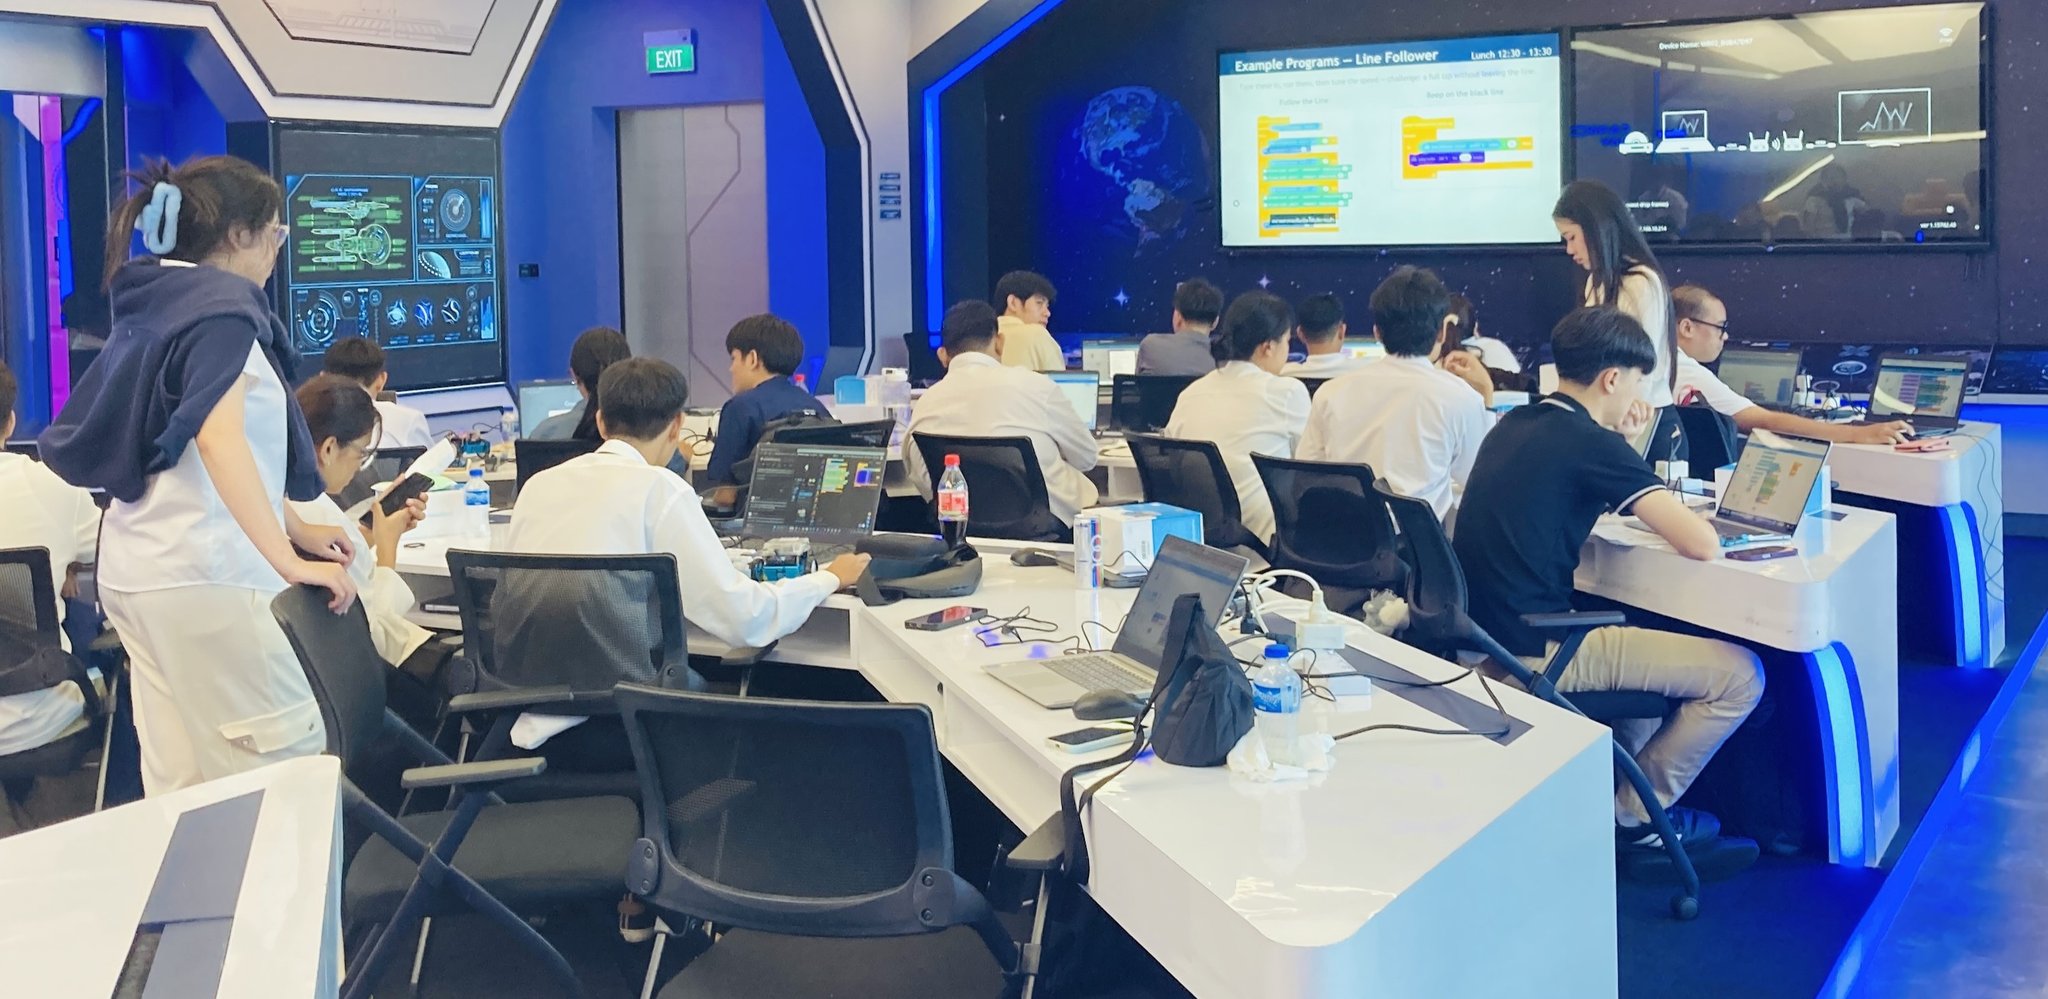
Everyone got their own mBot — a small blue two-wheeled robot with a big open circuit board on top. Instructor walked us through the parts: two DC motors, a line-follower sensor underneath, an ultrasonic distance sensor in the front (looks like eyes), a buzzer, RGB LEDs, and the mCore mainboard running an Arduino-based chip.
Then we opened mBlock 5 on the laptops. Block-based like Scratch — you drag and snap blocks instead of typing code. First warm-up: make the mBot go forward, stop, back up, turn left, turn right. Basic, but good for getting the muscle memory.
Now the fun part. The line-follower sensor underneath the mBot has 2 IR(infrared) that read the surface. Black absorbs infrared, white reflects it — so the sensor can tell if it's over black tape or white paper.
The logic:
Built this with block code and tested on a taped black-line track. First run: my mBot immediately spun in circles. Debug time. Turned out my left and right motor blocks were swapped. Fixed it, ran again, and it followed the whole track. Small win, felt huge.
After lunch, second mission: make the mBot avoid obstacles. The ultrasonic sensor in front sends out sound pulses and measures how long they take to bounce back — which gives you distance in centimetres.
The logic:
Sounds simple. In practice, the robot kept turning into the obstacle because my turn timer was too short. Bumped it from 500 ms to 800 ms and it worked. Also learned that shiny or angled surfaces confuse the ultrasonic sensor because the sound bounces off sideways instead of coming back to the receiver.
Final boss: follow the black line AND avoid obstacles placed on the track. This means the code has to check both sensors every loop and decide priorities. My logic:
My mBot mostly made it. Missed one obstacle and clipped a corner, but crossed the line. Some teams got a full clean run. Vibe was great — everyone helping each other debug, instructors walking around answering questions.
Instructors ran through the day, showed off some of the best runs, and reminded us tomorrow's session is AI Essentials — the module that leads to the Google AI Essentials certification. Packed up laptops, formal outfit still holding up somehow, and boarded the coach back to the hotel.
Actually built something today that moved, sensed, and reacted. Different energy from just watching lectures or reading slides. Also confirmed I like the hardware + code combo — you can literally see your bug when the robot drives into a wall, which makes debugging weirdly satisfying. Tomorrow: AI Essentials. Bringing the same energy. Goodnight.
Photo journal
22 Photos