Day 04Report
🇸🇬 Singapore Trip Report — Day 4
- Date
- 09 September 2026
- Location
- Singapore
- Reading time
- 6 min read
- Photos
- 14 Photos
Day 04Report
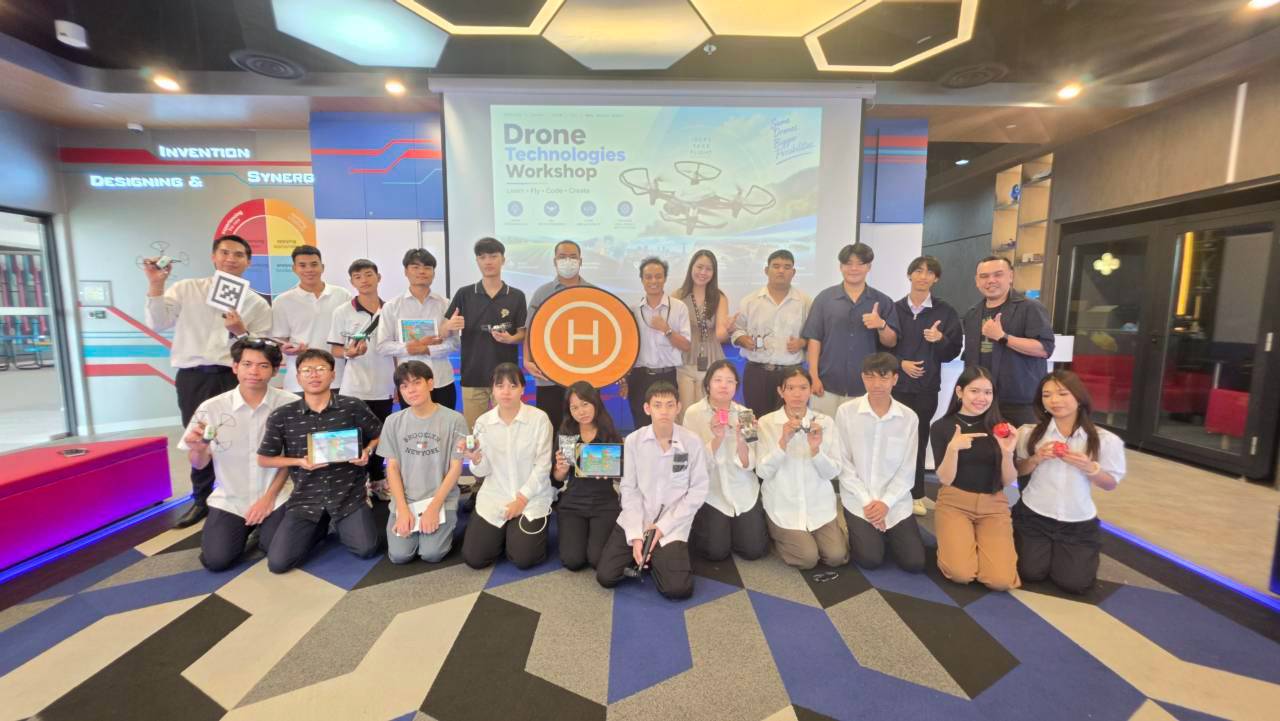
Back at ITE College East, but today the robots leave the floor and take to the air. Drone workshop day — programming the HULA DRONE with block coding to take off, fly patterns, and land on target. Yesterday was 2D, today is 3D, and the difference is bigger than I expected.
Same routine as yesterday. Breakfast, formal outfit, out the door. Same chartered coach picking us up outside the hotel, same 45-minute ride east through Bugis, past the CBD, out towards Simei. Bus AC still cranked. Group energy noticeably higher though — everyone's excited because drones.
Different room this time. Instead of the robotics lab we used yesterday, we got a bigger open space with soft mats on the floor and safety netting around the flight zone — because drones flying into people or walls is a real thing. Instructors did a proper safety briefing before anyone touched a drone. No hoodies, no loose sleeves near propellers, phones out of the flight zone.
Got introduced to the HULA DRONE — a small educational quadcopter (4 rotors) with propeller guards for indoor safety. Lightweight, palm-sized, connects wirelessly to the laptop. Instructor broke down the parts: 4 motors, 4 propellers (2 spin clockwise, 2 counter-clockwise to cancel torque), flight controller board with a built-in gyroscope + accelerometer (IMU) for stability, a barometer for altitude, and the battery — good for about 7 minutes per charge.
Then we opened the block-coding app. Same idea as mBlock from yesterday — drag blocks, snap them together, click run. First blocks we tried: takeoff, wait 3 seconds, land. That's it. A full working program in 3 blocks.
Nerves. Real nerves. Clicked "run" and my drone lifted off, hovered for 3 seconds at about waist height, then landed. It just… worked. I know it's basic but seeing your own code make a physical object leave the ground is a completely different feeling from watching a wheel spin.
Second attempt added a bit of movement — takeoff, forward 50 cm, wait, land. Went slightly further than expected because I didn't account for drift. Still landed inside the net. Small win.
After lunch, we went deeper. Instructor introduced the three axes of drone movement:
Also altitude (up/down) which is separate. So a drone has 4 controls at once, vs the mBot which just had 2 wheel speeds. Way more to think about.
Coded a sequence: takeoff → forward 1 m → turn right 90° → forward 1 m → turn right 90° → forward 1 m → turn right 90° → forward 1 m → land. If the drone flew a clean square, the code worked. Mine did most of a square — the last turn was under-rotated so it landed slightly off. Adjusted the turn time by 200 ms and got it right on the third try.
Final task: program a full autonomous mission — takeoff, fly a set pattern through checkpoints (marked on the floor with cones and small hoops), and land on a target square. No manual control allowed. Just press run and hope.
My mission plan: takeoff → forward → up → forward through the hoop → right → down → land on target. Took 4 attempts. Failed 1 (landed off-target), failed 2 (hit the hoop edge), failed 3 (drifted too far left). Attempt 4 — clean run. Landed dead centre on the target square. First time all week I actually cheered out loud.
Instructors ran through everyone's mission runs, pointed out cool solutions, and gave feedback. Reminded us tomorrow is AI Robotics — the last hands-on module before certification. Packed up, formal shirt now visibly wrinkled but I don't even care, boarded the coach back to the hotel.
Flew something today. That's a sentence I couldn't have written a week ago. Also confirmed what I felt after Day 3 — I really like this code + physical hardware combo. When it works, you see it work. When it fails, you see that too, usually spectacularly. Tomorrow: AI Robotics. Final training day before the cert exam. Bringing it. Goodnight.
Photo journal
14 Photos